Autonomous competition robot
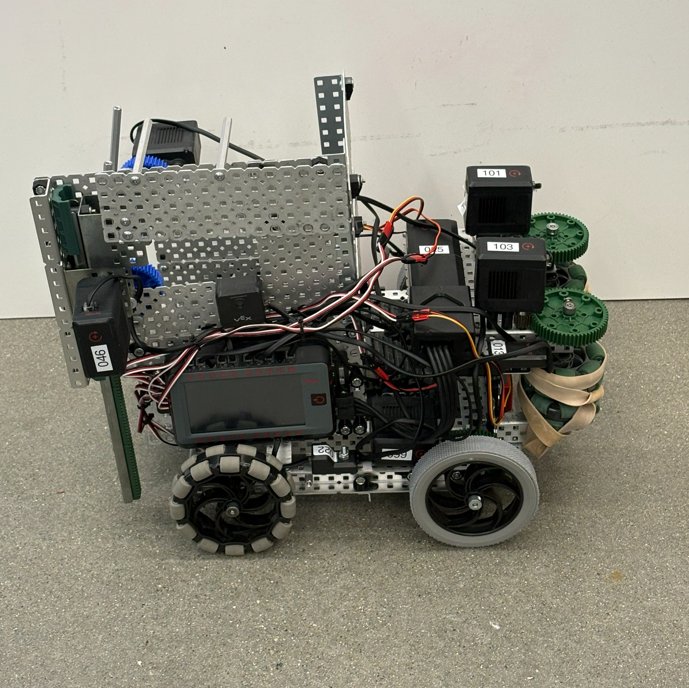
The full autonomous and driver-controlled software for a VEX V5 robot in a timed harvesting game: autonomously find a fake tree, pick its fruit, deposit the fruit in a basket, and repeat. Our team took first in the class competition. Three days of work against a hard deadline.
Two pieces I’d build the same way again. The lift homes itself by driving down until it stalls and then backing off a fixed amount, which gives you a repeatable zero position without a limit switch. And to aim at a cylindrical target, the robot sweeps until it loses the edge on one side, sweeps back until it loses the other, and splits the difference, which is far more reliable than trying to find the center directly.
The thing that outlasted the competition was the documentation. I kept a running engineering reference of platform behavior that isn’t in the vendor docs, and it ended up at nearly a thousand lines covering port mapping, field geometry, control patterns, and fifteen failure modes I actually hit and tested. Things like which vision class works versus which one silently doesn’t, and why commanding 100 percent motor power gives you less than maximum torque under load.